Projects
Research in learning-based manipulation, simulation, and contact-aware control.
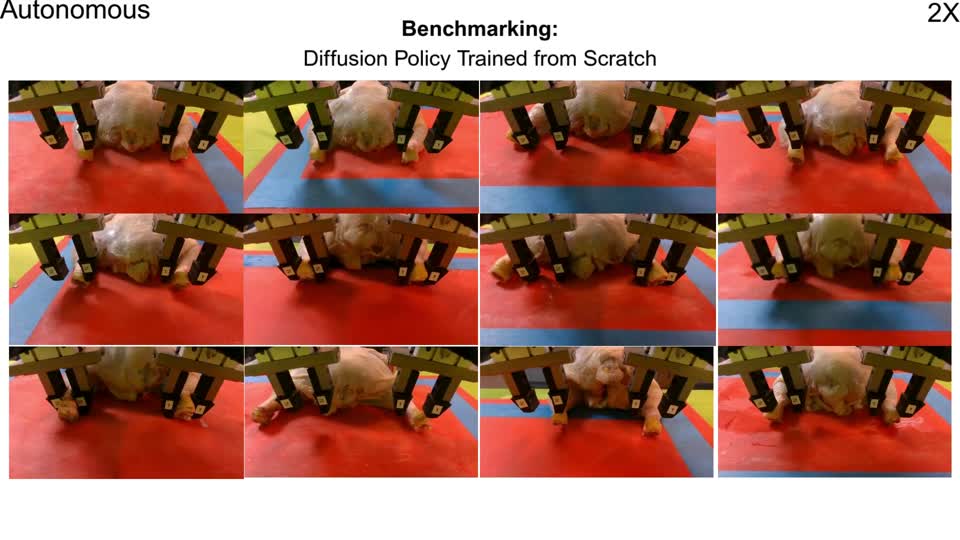
Real-world robot learning
ChicGrasp
Imitation learning for manipulation of delicate, irregular bio-products.
Diffusion Policy · UR10e · Custom gripper · Multi-view vision
Project details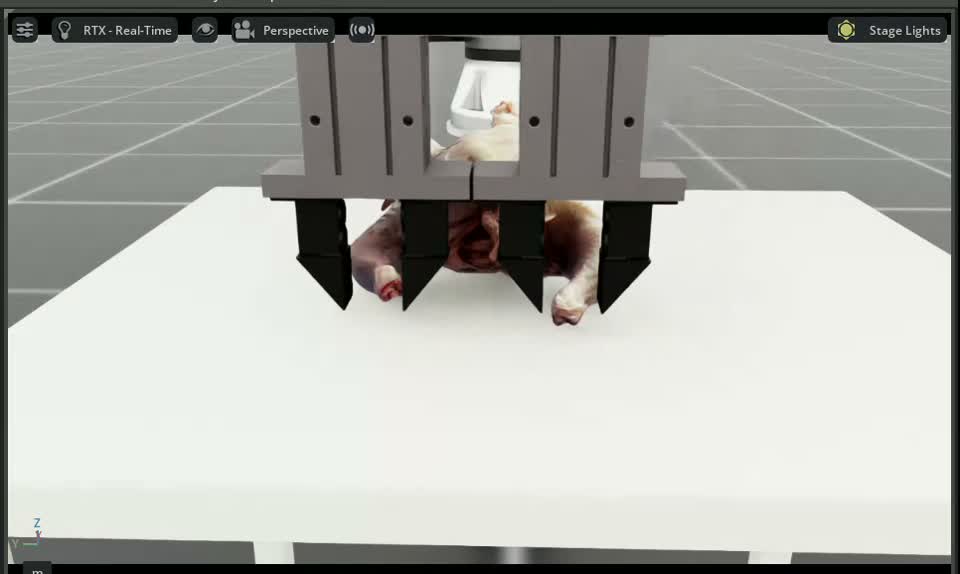
Simulation & imitation learning
Learning-based deformable-object manipulation
Simulation, teleoperation, and policy learning in NVIDIA Isaac Lab.
Isaac Lab · UR10e · Diffusion Policy · Teleoperation
Project details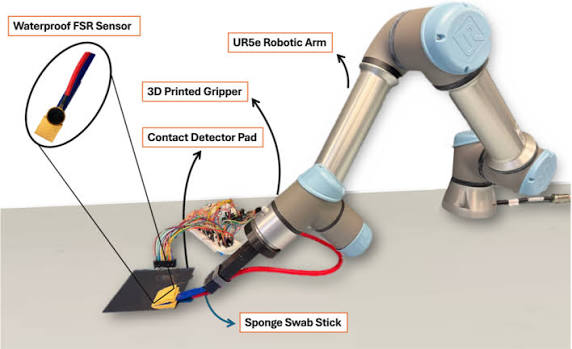
Tactile sensing & control
Contact-aware deformable tool manipulation
Tactile feedback and adaptive control for robotic environmental swabbing.
Tactile sensing · Koopman control · Deformable tools
Project details