Publications
Selected journal articles and conference presentations.
Google Scholar ↗Download BibTeX ↓
Journal articles
2026
- Adv. Robot. Res.
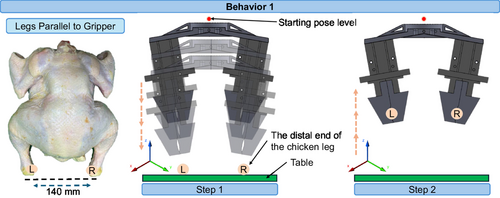 ChicGrasp: Imitation-Learning-Based Customized Dual-Jaw Gripper Control for Manipulation of Delicate, Irregular Bio-ProductsAdvanced Robotics Research, 2026
BibTeX
@article{davar2026chicgrasp, title = {ChicGrasp: Imitation-Learning-Based Customized Dual-Jaw Gripper Control for Manipulation of Delicate, Irregular Bio-Products}, author = {Davar, Amirreza and Xu, Zhengtong and Mahmoudi, Siavash and Sohrabipour, Pouya and Pallerla, Chaitanya and She, Yu and Shou, Wan and Crandall, Philip Glen and Wang, Dongyi}, journal = {Advanced Robotics Research}, year = {2026}, doi = {10.1002/adrr.202500149}, html = {https://doi.org/10.1002/adrr.202500149}, code = {https://github.com/AmirrezaDavar/ChicGrasp}, website = {https://amirrezadavar.github.io/ChicGrasp/}, preview = {chicgrasp-journal.jpg}, selected = {true}, bibtex_show = {true}, abbr = {Adv. Robot. Res.} } - Adv. Robot. Res.
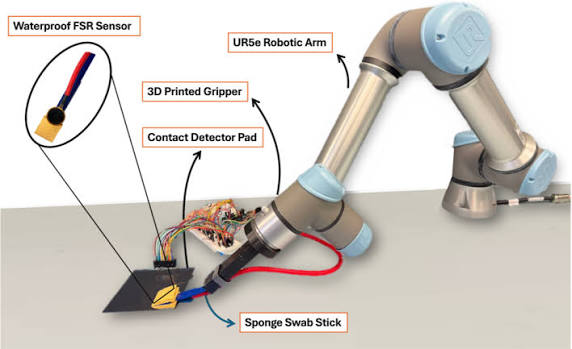 A State-Adaptive Koopman Control Framework for Real-Time Deformable Tool Manipulation in Robotic Environmental SwabbingAdvanced Robotics Research, 2026
BibTeX
@article{mahmoudi2026koopman,
  title = {A State-Adaptive Koopman Control Framework for Real-Time Deformable Tool Manipulation in Robotic Environmental Swabbing},
  author = {Mahmoudi, Siavash and Davar, Amirreza and Wang, Dongyi},
  journal = {Advanced Robotics Research},
  year = {2026},
  doi = {10.1002/adrr.202500142},
  html = {https://doi.org/10.1002/adrr.202500142},
  arxiv = {2503.21491},
  preview = {contact-aware.jpg},
  bibtex_show = {true},
  abbr = {Adv. Robot. Res.}
}
2024
- Front. Robot. AI
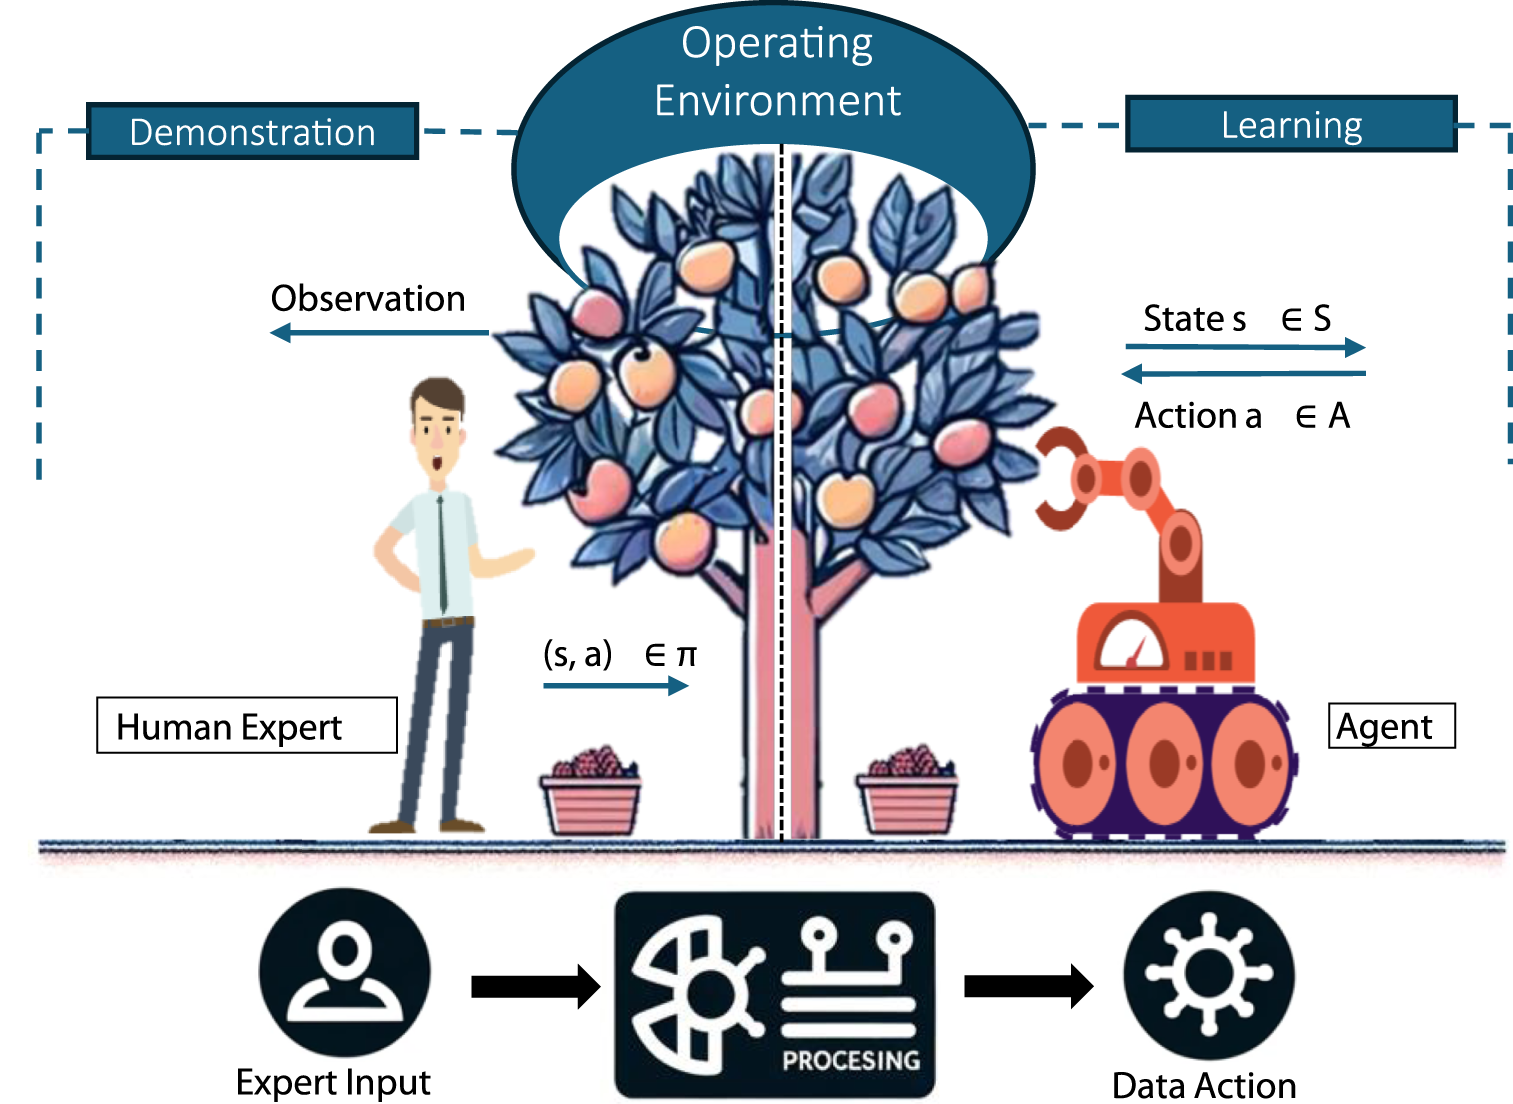 Leveraging Imitation Learning in Agricultural Robotics: A Comprehensive Survey and Comparative AnalysisFrontiers in Robotics and AI, 2024
BibTeX
@article{mahmoudi2024survey,
  title = {Leveraging Imitation Learning in Agricultural Robotics: A Comprehensive Survey and Comparative Analysis},
  author = {Mahmoudi, Siavash and Davar, Amirreza and Sohrabipour, Pouya and Bist, Ramesh Bahadur and Tao, Yang and Wang, Dongyi},
  journal = {Frontiers in Robotics and AI},
  volume = {11},
  pages = {1441312},
  year = {2024},
  doi = {10.3389/frobt.2024.1441312},
  html = {https://doi.org/10.3389/frobt.2024.1441312},
  preview = {imitation-learning-survey.jpg},
  selected = {true},
  bibtex_show = {true},
  abbr = {Front. Robot. AI}
}
Conference presentations
2025
- ICRA poster
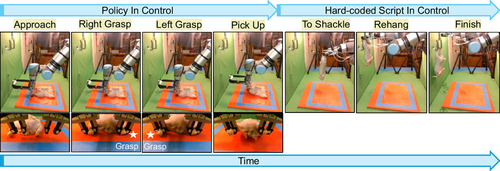 ChicGrasp: Imitation-Learning Control for Dual-Finger Manipulation of Delicate, Irregular, and Bio-productsInternational Conference on Robotics and Automation (ICRA), poster presentation, 2025
BibTeX
@misc{davar2025chicgrasp_poster,
  title = {ChicGrasp: Imitation-Learning Control for Dual-Finger Manipulation of Delicate, Irregular, and Bio-products},
  author = {Davar, Amirreza and Xu, Zhengtong and Mahmoudi, Siavash and She, Yu and Shou, Wan and Wang, Dongyi},
  year = {2025},
  howpublished = {International Conference on Robotics and Automation (ICRA), poster presentation},
  note = {Poster presentation},
  html = {https://sfelab.uark.edu/proceedings-and-presentations/},
  preview = {chicgrasp-icra.jpg},
  bibtex_show = {true},
  abbr = {ICRA poster}
}