ChicGrasp
Imitation learning for manipulation of delicate, irregular bio-products.
ChicGrasp combines a UR10e robot, an independently actuated dual-jaw pneumatic gripper, multi-view observations, and a diffusion policy trained from human demonstrations. The system studies robotic grasping and handling of irregular, deformable poultry objects.
Publication
2026
- Adv. Robot. Res.
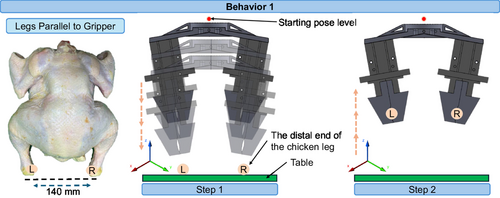 ChicGrasp: Imitation-Learning-Based Customized Dual-Jaw Gripper Control for Manipulation of Delicate, Irregular Bio-ProductsAdvanced Robotics Research, 2026
BibTeX
@article{davar2026chicgrasp,
  title = {ChicGrasp: Imitation-Learning-Based Customized Dual-Jaw Gripper Control for Manipulation of Delicate, Irregular Bio-Products},
  author = {Davar, Amirreza and Xu, Zhengtong and Mahmoudi, Siavash and Sohrabipour, Pouya and Pallerla, Chaitanya and She, Yu and Shou, Wan and Crandall, Philip Glen and Wang, Dongyi},
  journal = {Advanced Robotics Research},
  year = {2026},
  doi = {10.1002/adrr.202500149},
  html = {https://doi.org/10.1002/adrr.202500149},
  code = {https://github.com/AmirrezaDavar/ChicGrasp},
  website = {https://amirrezadavar.github.io/ChicGrasp/},
  preview = {chicgrasp-journal.jpg},
  selected = {true},
  bibtex_show = {true},
  abbr = {Adv. Robot. Res.}
}