Contact-aware deformable tool manipulation
Tactile feedback and adaptive control for robotic environmental swabbing.
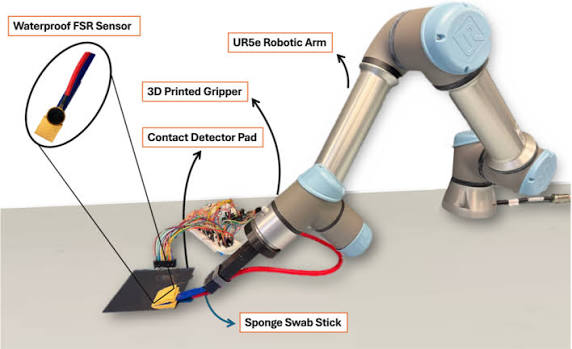
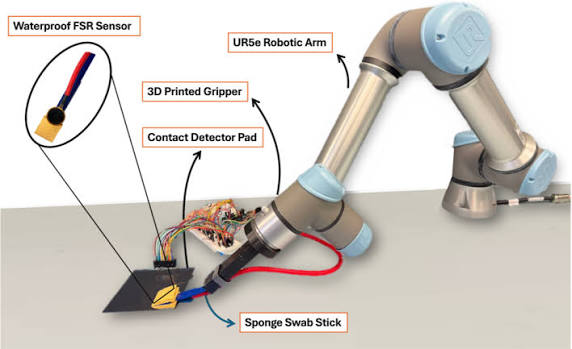
This coauthored research studies environmental swabbing with a deformable tool. A state-adaptive Koopman control framework uses tactile feedback to regulate contact during robotic manipulation.
Publication
2026
- Adv. Robot. Res.
 A State-Adaptive Koopman Control Framework for Real-Time Deformable Tool Manipulation in Robotic Environmental SwabbingAdvanced Robotics Research, 2026
BibTeX
@article{mahmoudi2026koopman,
  title = {A State-Adaptive Koopman Control Framework for Real-Time Deformable Tool Manipulation in Robotic Environmental Swabbing},
  author = {Mahmoudi, Siavash and Davar, Amirreza and Wang, Dongyi},
  journal = {Advanced Robotics Research},
  year = {2026},
  doi = {10.1002/adrr.202500142},
  html = {https://doi.org/10.1002/adrr.202500142},
  arxiv = {2503.21491},
  preview = {contact-aware.jpg},
  bibtex_show = {true},
  abbr = {Adv. Robot. Res.}
}